The road-going response of an electric vehicle depends on much more than a single peak power figure
Drivers usually remember what a performance electric car does in the first second after they press the accelerator. There is no rising engine note, no conventional multi-gear shift, and often very little delay between the request and the surge forward. The easy explanation is “instant torque.” It is catchy, but it leaves out most of the engineering that actually determines how quick an EV feels.
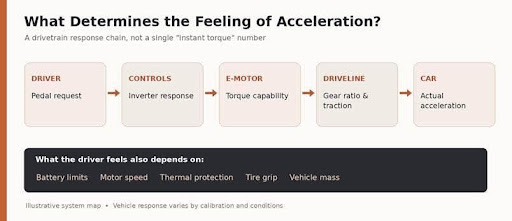
An electric motor can respond rapidly because torque is controlled electronically, yet the driver experiences the combined behavior of the battery, inverter, motor, final-drive gearing, tires, and vehicle software. Two cars with similar peak power outputs may therefore deliver noticeably different launches, passing response and smoothness. Looking at the complete drive system tells a better story than comparing horsepower figures alone.
The pedal is a request, not a direct mechanical command
In a traditional combustion car, throttle and transmission behavior shape the acceleration request. In an EV, pressing the pedal typically sends an electronic torque demand to the vehicle controller. That demand is checked against traction, available battery power, motor speed, temperature, and stability limits before the inverter produces the required electrical currents.
One manufacturer may calibrate the first part of pedal travel to feel relaxed and progressive. Another may deliver much more wheel torque with a smaller movement. Both calibrations can use similar hardware. This explains why a city-focused electric crossover and a track-oriented performance EV can feel different even when their published torque numbers appear close.
Why the torque curve matters more than a headline number
Many electric traction drives can provide a broad region of strong low-speed torque. As motor speed rises, electrical and thermal limits increasingly govern what the drive can deliver, and available torque generally falls as the system moves into a power-limited region. The precise shape depends on motor design, voltage, current capability, and control strategy.
Gearing then turns motor torque into wheel torque. A higher reduction ratio can strengthen launch response but changes motor speed at a given road speed. Final gearing, tire radius, and driven axle configuration all matter. So does traction: a system that can produce huge motor torque still cannot accelerate faster than the tires and road surface allow.
The electric motor core is part of the performance equation
Inside a typical traction motor, electrical steel laminations form the stator and rotor cores that guide changing magnetic fields. Geometry, material grade, slot design, and manufacturing quality influence losses, temperature, mechanical stability, and electromagnetic behavior. Engineers selecting electric vehicle motor cores consider not only shape and dimensions but also the operating speed range, magnetic requirements and the way the final stack will be assembled.
The connection to acceleration is indirect but important. Motor losses become heat, and excessive temperature can limit continuous output or force the controller to reduce available torque. The motor that delivers an impressive short burst must also stay within its thermal and mechanical boundaries after repeated hard acceleration.
Repeated pulls tell a more useful story
A single strong launch is exciting. A second, third and fourth can be much more informative. Sustained performance depends on coolant flow, radiator capacity, inverter losses, battery temperature and how effectively heat moves out of the motor. Manufacturers set protection thresholds to defend hardware and battery life, so full output may not be available in every condition.
This does not mean a car is poorly engineered. Protecting the drive system is part of good design. The useful questions are how consistently the vehicle delivers torque, how transparently it reduces power when hot and whether its behavior remains predictable for the driver.
Manufacturing precision and drivetrain feel
The stack made from individual electrical-steel sheets needs controlled alignment, slot geometry and joint quality. Errors that affect air-gap uniformity or rotor balance can contribute to vibration and electromagnetic noise; the significance depends on the motor design. Engineers use materials, tooling and inspection together to limit manufacturing variation.
The role of e-mobility motor laminations therefore extends beyond headline efficiency figures. The production specification should support reliable assembly, appropriate magnetic properties and repeatable behavior in a rotating system that may operate over a broad speed range.
How to judge the feeling from the driver’s seat
When comparing EVs, try several real-world situations instead of relying on a launch demonstration. Note the response to a small pedal input at parking speeds, the transition from coasting to gentle acceleration, a mid-speed overtaking request and the smoothness of torque delivery while turning. If it is safe and legal, consider whether repeated acceleration produces a change in response.
Listen for unexpected tonal whine, feel for drivetrain shunt when power is applied and pay attention to how smoothly traction control intervenes. These are not laboratory measurements, but they reveal qualities the spec sheet cannot capture. A convincing electric performance car should be responsive without being abrupt, quick without drama and consistent when driven beyond a single spectacular launch.
The difference between peak performance and usable performance
Peak torque and peak power are typically obtained under defined operating conditions, but a driver’s acceleration request can happen with a low battery state of charge, on a hot day or after a long highway climb. The control system continuously balances available electrical power and thermal protection against the requested result. That balance is why identical pedal movements can produce different responses as conditions change. Some vehicles communicate these limits clearly, while others leave the driver to discover them through reduced performance.
For engineers, useful validation requires a test plan that looks beyond one acceleration number. Road and laboratory tests can compare response delay, wheel-torque smoothness, thermal stability and repeatability at several speeds and temperatures. Measurement helps distinguish a genuine motor limitation from tire behavior, gearing, traction intervention or deliberate pedal mapping. The same logic matters for manufacturers: stable magnetic-core geometry and repeatable assembly are inputs to consistent output, not guarantees of any particular zero-to-sixty time.
For an enthusiast, this suggests a simple way to read a specification sheet. Treat a claimed maximum torque figure as one piece of information, then look for acceleration performance at different speeds, how the vehicle manages heat and whether independent tests show repeatable results. A well-matched drivetrain often feels more confident in everyday driving than one optimized only for an impressive launch headline.
The takeaway
“Instant torque” remains a useful introduction to electric driving. It is not a full explanation. The compelling part of the experience comes from matching motor construction, power electronics, gearing, thermal capacity, traction and software into one coherent system. Drivers ultimately feel that integration, not the isolated maximum rating of any one component.